Reinforcement learning · Research
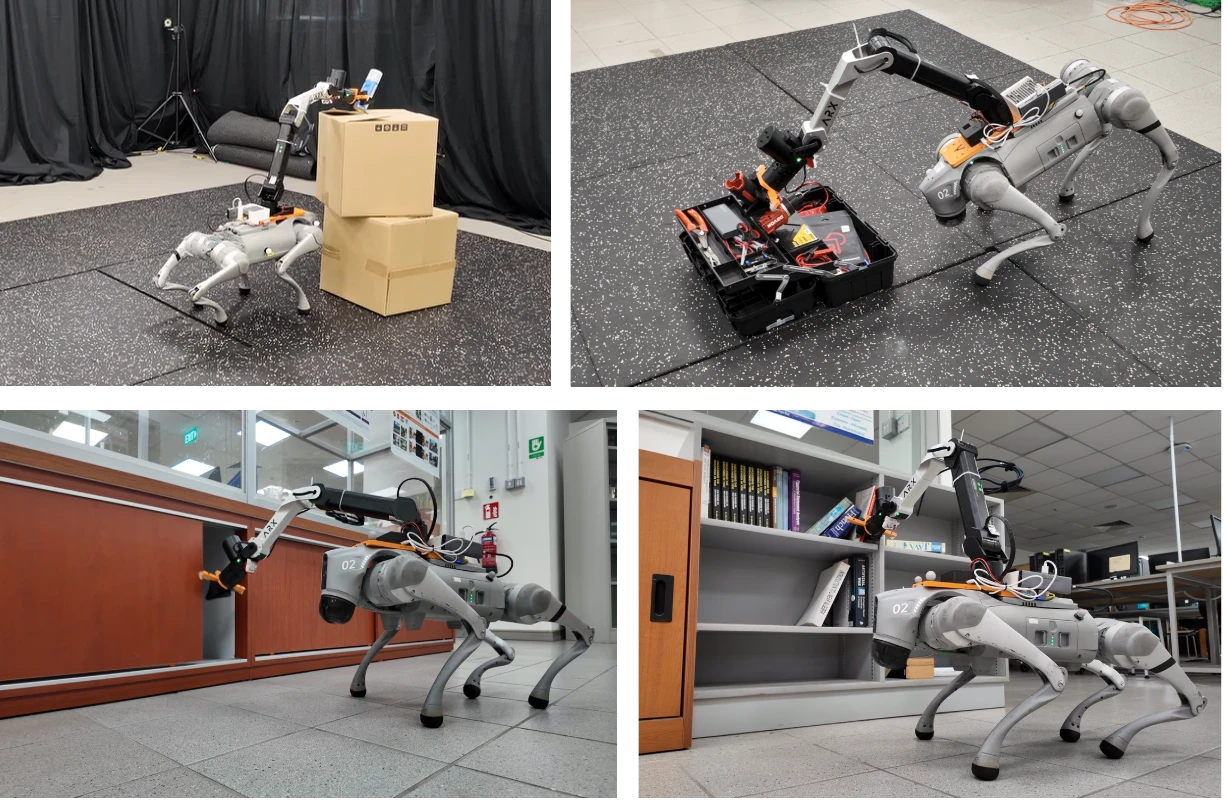
Legged mobile manipulation
Building a unified benchmark, reproducing learning-based methods, and studying coordinated quadruped locomotion and arm control.
50SE(3) evaluation trajectories
View project Robotics · Embodied AI
MSc Robotics student at the National University of Singapore. My interests span legged manipulation, reinforcement learning, and embodied AI, with hands-on experience in mechanics, control, perception, navigation, and real-robot deployment.
National University of Singapore
MSc in Robotics
Xi’an Jiaotong-Liverpool University
BEng in Mechatronics and Robotic Systems
Building a unified benchmark, reproducing learning-based methods, and studying coordinated quadruped locomotion and arm control.
Connecting mapping, relocalization, and floor-aware mission management for indoor navigation on a Unitree robot.
View projectConnecting visual recognition, robot movement, and spoken narration in a perception–decision–action loop.
View projectDesigning a compact arm and specialized gripper for home settings, with magnetic-encoder feedback for closed-loop stepper control.
View projectBuilding an Autoware-based delivery platform from chassis and suspension to powertrain and sensor integration.
View projectMay 2026 — Present
Hangzhou, ChinaEmbodied AI Intern
Jul 2025 — Aug 2025
Changzhou, ChinaRobotics R&D internship
arXiv · 2026 · Under review
IEEE EECR 2026 · pp. 243–248
RiTA · Springer LNNS 1132 · 2024 · pp. 321–335
National third prize · Northern regional first prize
National second prize · Northern regional first prize
Second edition · Second prize
Three consecutive Academic Excellence Awards (ranked 2nd in years 1–2 and 1st in year 3) · Graduate Best Overall Award · University Outstanding Student · Provincial Outstanding Student
arXiv · Robotics
Following developments in embodied AI, robot learning, and control. Browse curated papers and Chinese–English abstracts by date.
ROS · Linux · Systems
Notes on environment setup and system experiments, alongside browser tools used in everyday development.
Python · C / C++
ROS / ROS 2 · Isaac Gym · MuJoCo
OpenCV · YOLOv8
Ubuntu · Git · LaTeX
Chinese (native) · English · IELTS 6.5
Open to conversations about robotics algorithms, embodied AI roles, and project collaborations.